Hi! I'm Soham — a Robotics & Control Engineer with a mechanical engineering base and a real love for control theory and deep learning. I build smart robots and 3D sims, always chasing what excites me 🚀
Contribution activity — last 12 months
Autonomous navigation for a Crazyflie 2.1 micro-UAV in fire-affected indoor environments, using only local temperature feedback and no prior map of the thermal field. Realistic fire scenarios were simulated via PyroSim/FDS and analytical superposition models, then evaluated with Greedy Hill Climbing, Epsilon-Greedy, and UCB multi-armed bandit strategies across single-source, multi-source, and sink-distorted thermal landscapes.


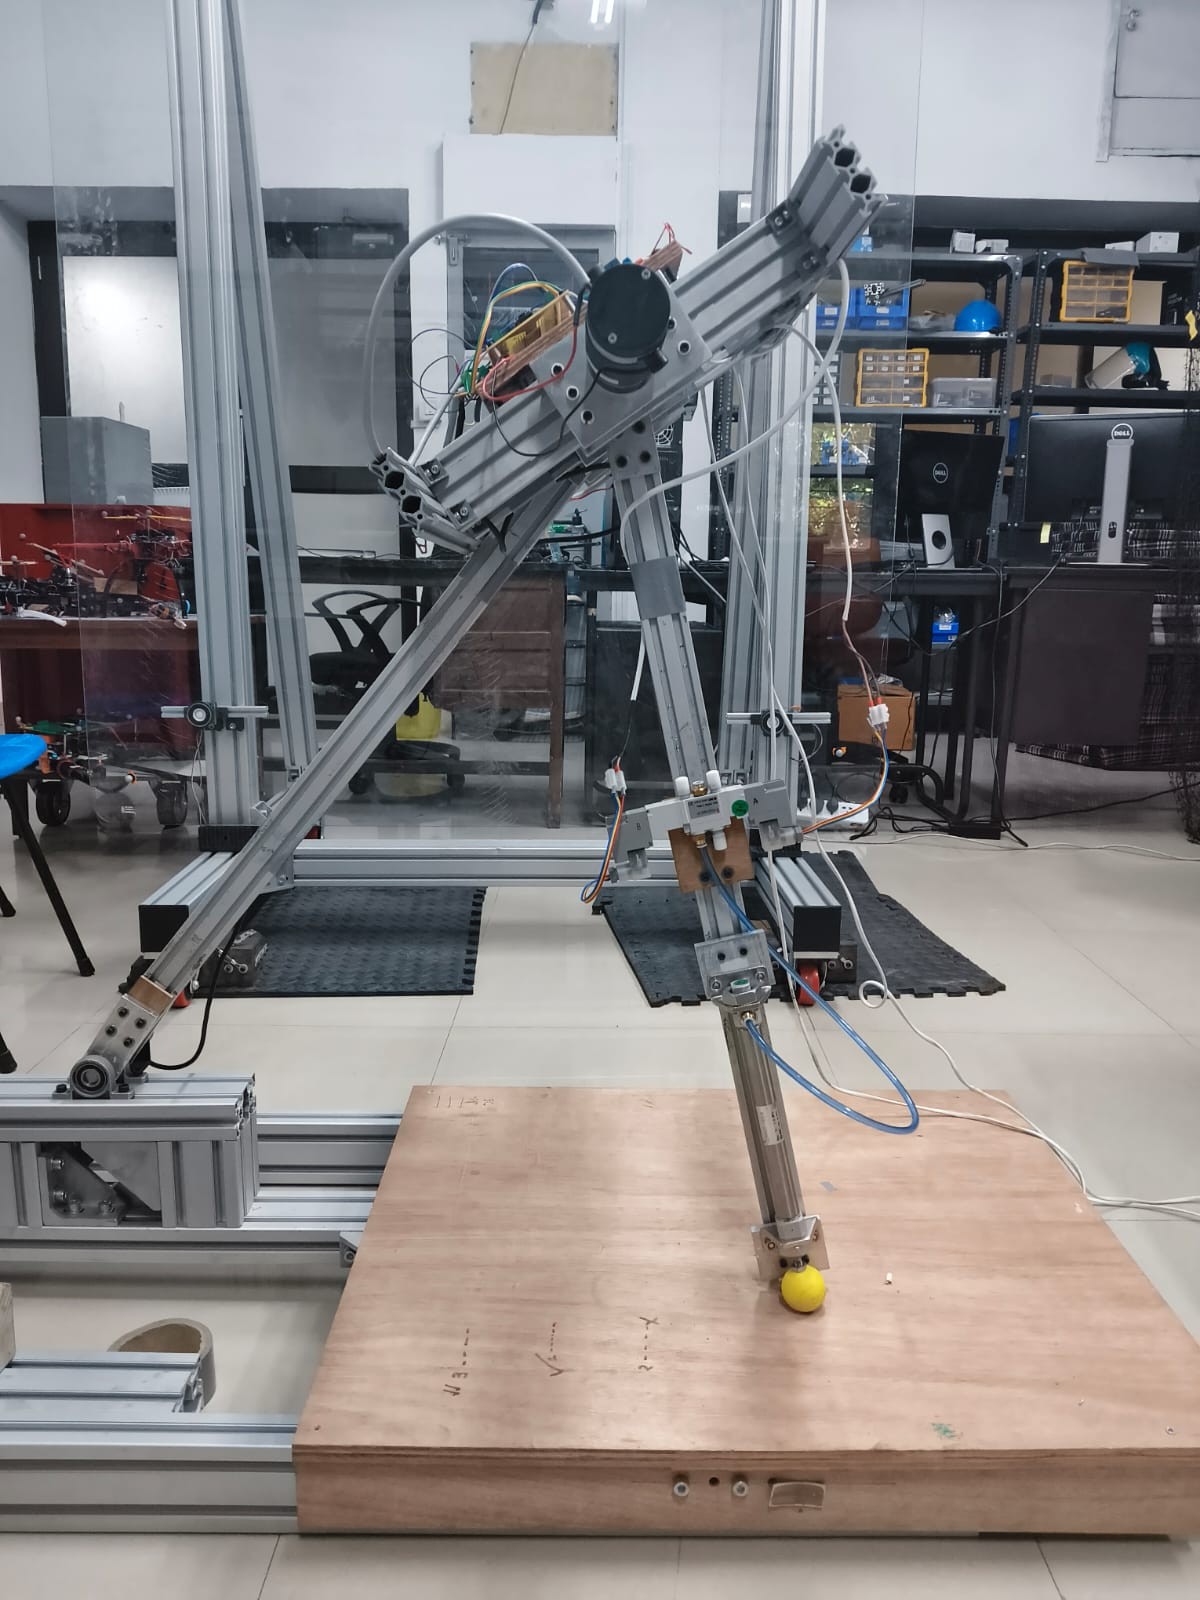
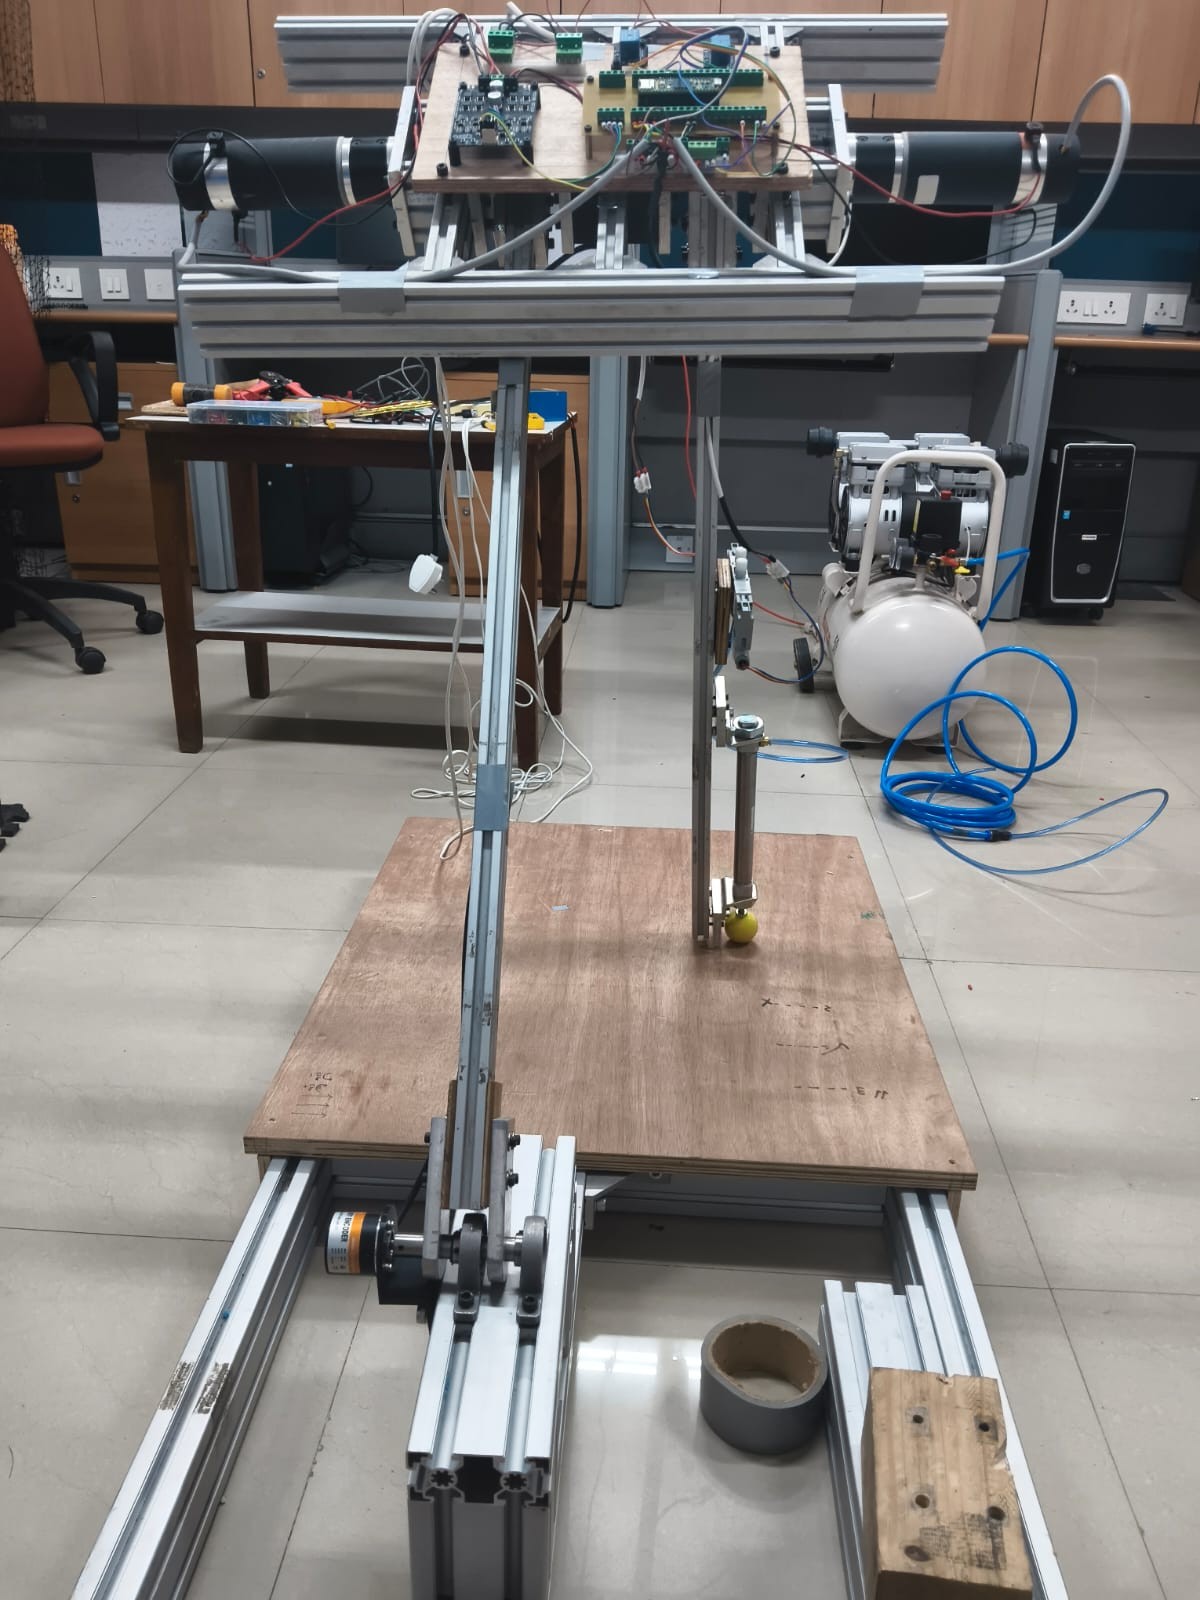
Open- and closed-loop control for an underactuated planar bipedal robot with pneumatic ankle push-off actuation, investigating precise impulse control during double-support transition phases. Built a unified modeling, simulation, and experimental framework from scratch, evaluating PID and Model Predictive Control (MPC) across multiple initial configurations and step sizes on both simulation and hardware-in-the-loop dSPACE setups to ensure gait stability and robust step tracking.

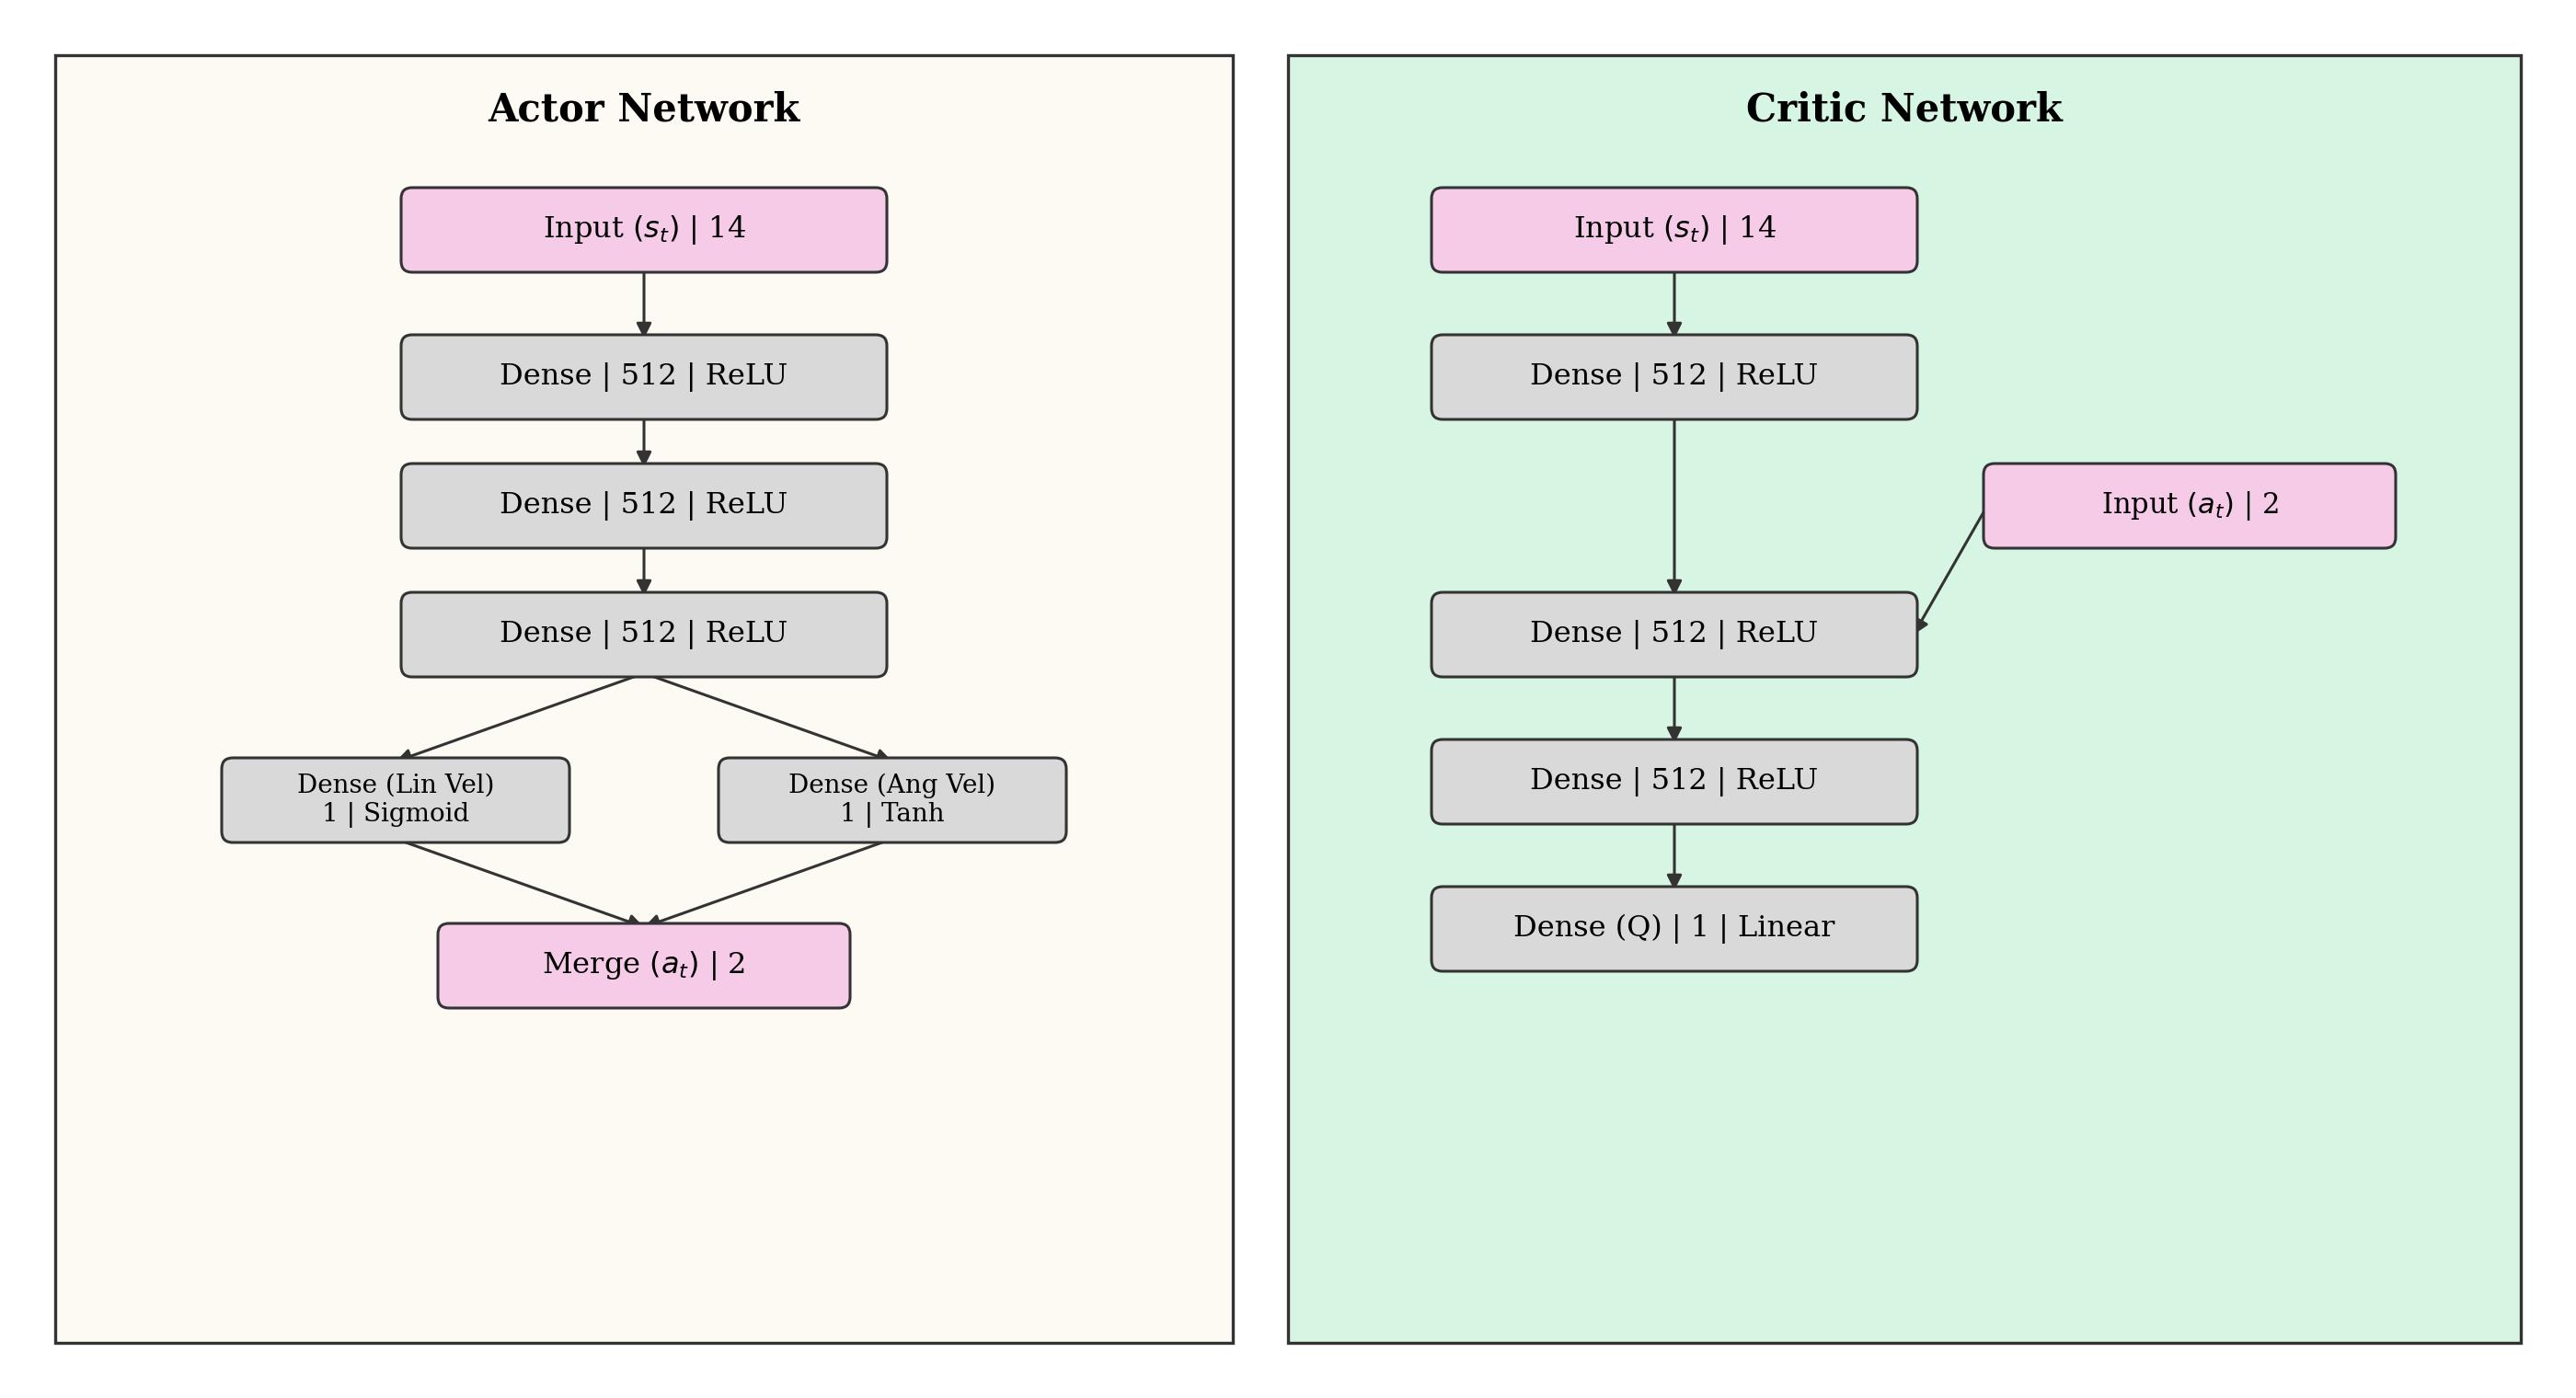
An asynchronous actor-critic (ADDPG) framework for continuous control of differential-drive mobile robots, using a compressed 14-dimensional state of sparse laser readings, relative target position, and previous velocity commands to output smooth linear and angular velocity commands. Trained entirely in PyBullet simulation and transferred to a physical Kobuki-based TurtleBot without any real-world fine-tuning, achieving collision-free mapless navigation at roughly 100 Hz control frequency.
Configuration-space (C-space) modeling for a nonholonomic differential-drive TurtleBot, treating every pose as a point in the SE(2) manifold and inflating workspace obstacles via Minkowski sums to build free space. Benchmarked deterministic A* grid search against sampling-based RRT for planner efficiency, path length, and obstacle clearance, then closed the sim-to-real gap on hardware using AMCL localization over laser scans and an adaptive Pure Pursuit controller to compensate for wheel slip and onboard processing latency.
Formulated and implemented an open-loop 2D drone trajectory optimization framework with double-integrator dynamics, Runge-Kutta 4th Order (RK4) discretization, and a smooth Softplus-based non-convex obstacle penalty. Optimized via CasADi's IPOPT solver to balance control effort, jerk minimization, terminal goal-reaching, and collision avoidance, then validated the resulting trajectories on real quadrotor hardware.
Find out more projects on my GitHub page
GitHub
Photo coming soon
Photo coming soon
Photo coming soon
Photo coming soon