Projects
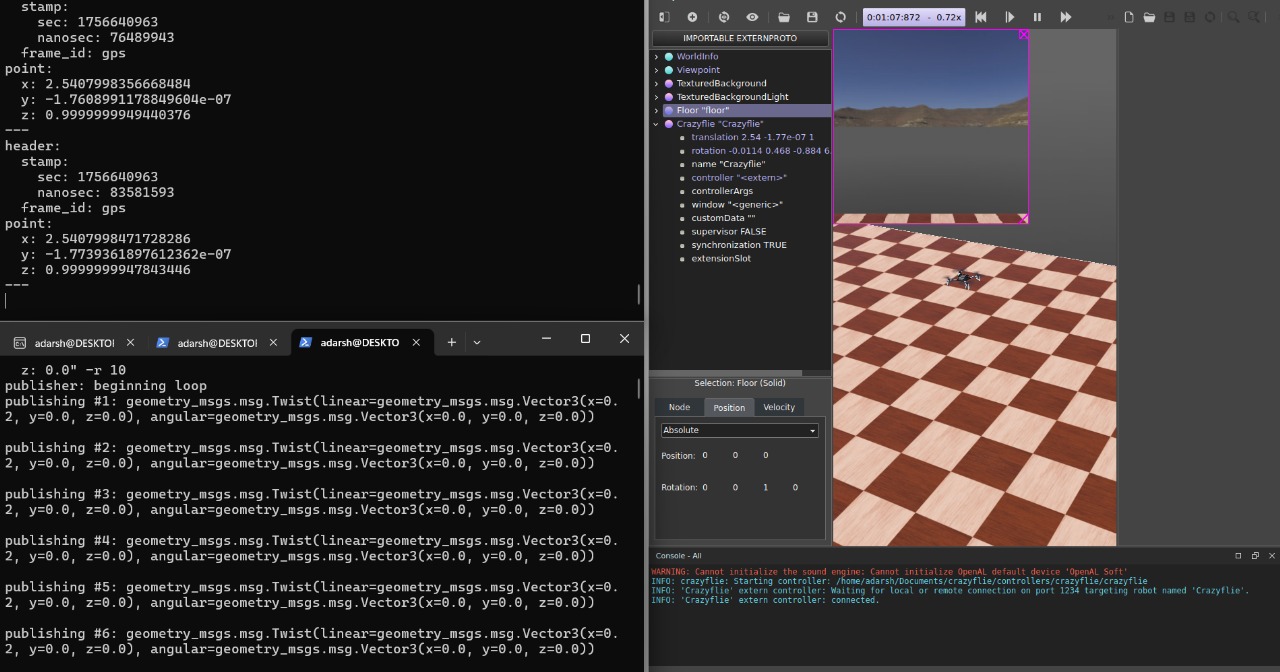
Autonomous Navigation in Fire Environment using Drone
Developed an autonomous navigation framework for a Crazyflie 2.1 micro-UAV operating in fire-affected environments using temperature feedback. Simulated realistic thermal environments via Pyrosim/FDS and analytical models, and evaluated reinforcement-learning strategies (Greedy, Epsilon-Greedy, UCB) for fire source localization across single-source, multi-source, and sink-distorted thermal landscapes.
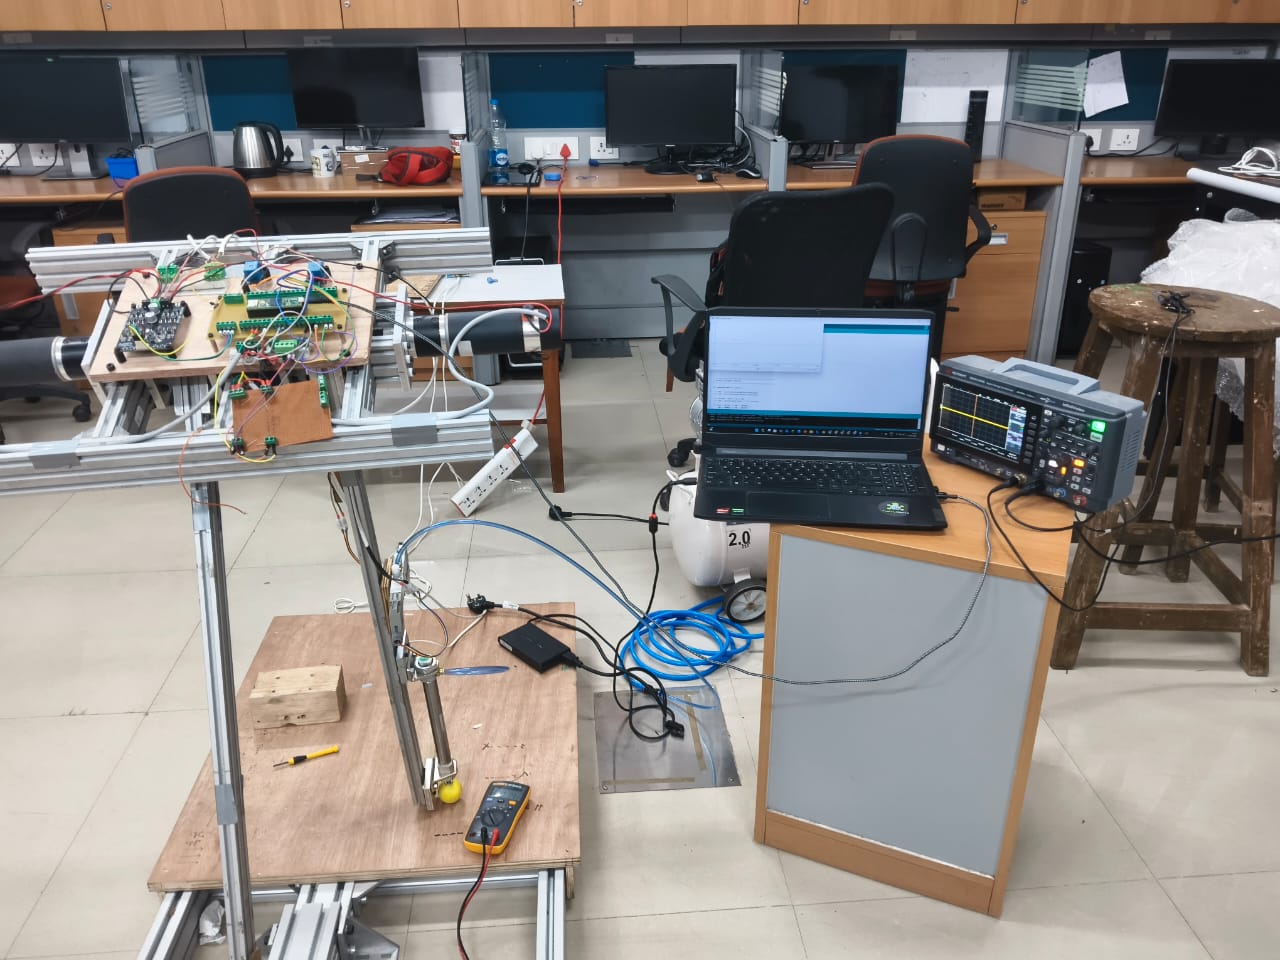
Control of Underactuated Bipedal Locomotion with Ankle Push-Off
Formulated, modeled, and implemented an open-loop and closed-loop control framework for an underactuated planar bipedal robot featuring pneumatic ankle push-off actuation. Evaluated PID and Model Predictive Control (MPC) strategies in simulation and hardware setups.
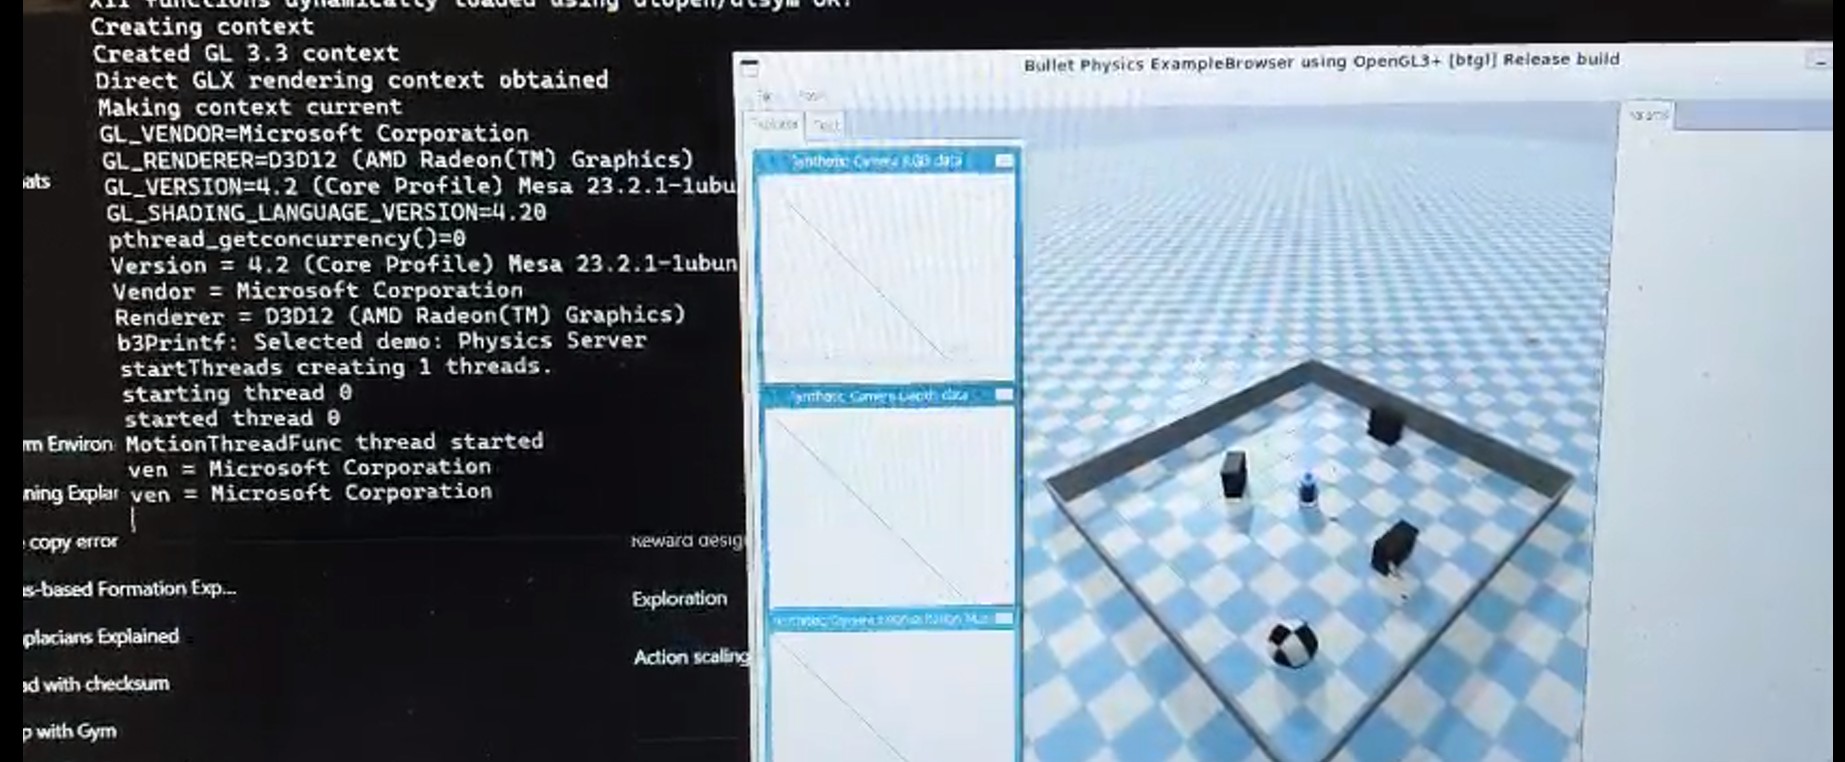
Virtual-to-Real Mapless Navigation via Deep Reinforcement Learning
Implemented an asynchronous actor-critic deep reinforcement learning (ADDPG) framework for continuous control of differential-drive mobile robots. Achieved mapless navigation using 10-dimensional sparse range findings and target coordinates, bridging the sim-to-real gap without fine-tuning.
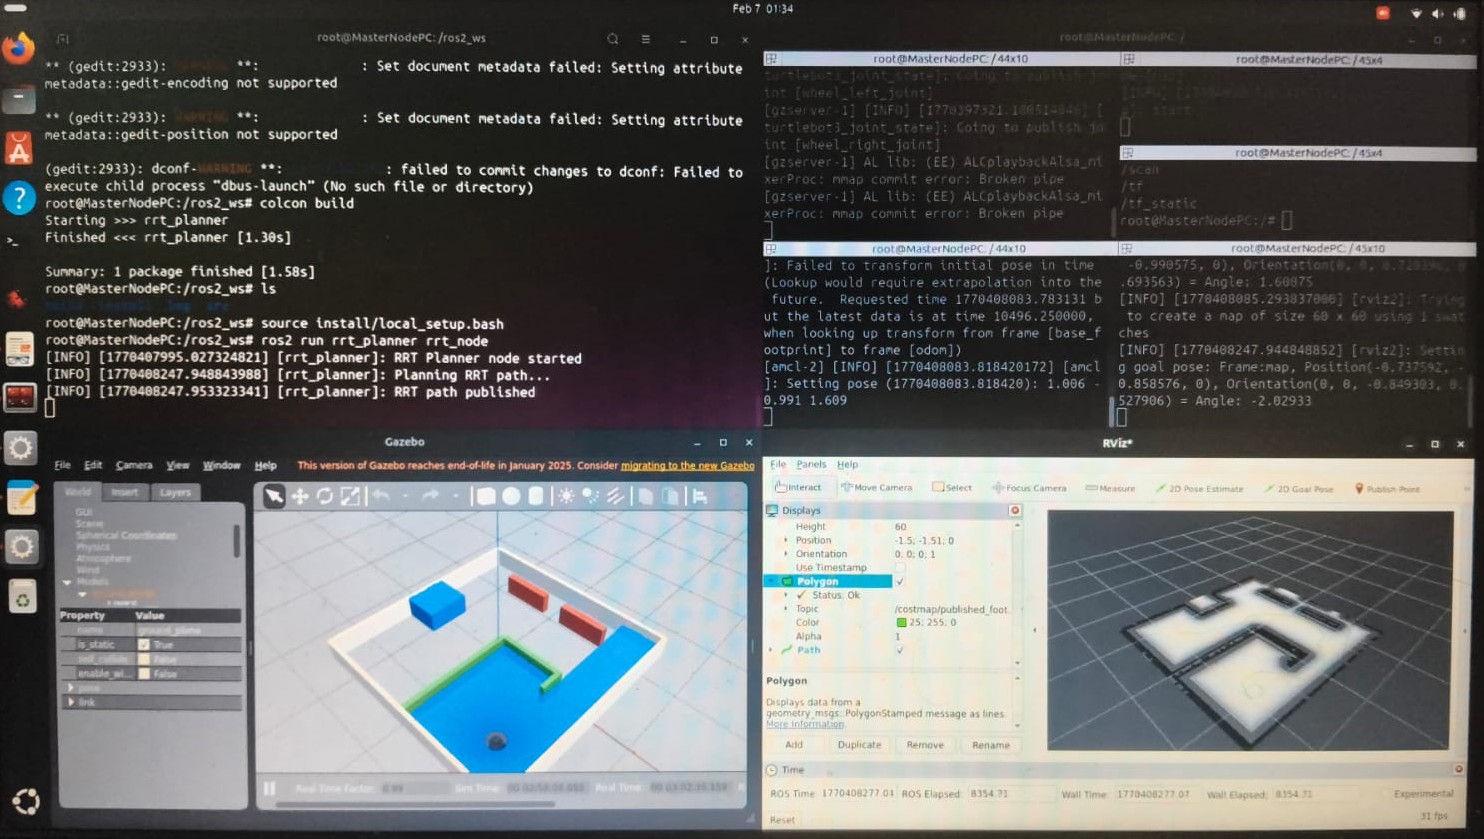
Motion Planning and Coordination for Autonomous Vehicles (TurtleBot)
Implemented configuration space (C-space) modeling, grid-based search (A*), and sampling-based motion planning (RRT) for a nonholonomic differential-drive TurtleBot. Benchmarked planner efficiency, path length, and obstacle clearance, and resolved sim-to-real deployment challenges using AMCL localization and Pure Pursuit path tracking.
Receding Horizon Control for Autonomous Crazyflie Navigation
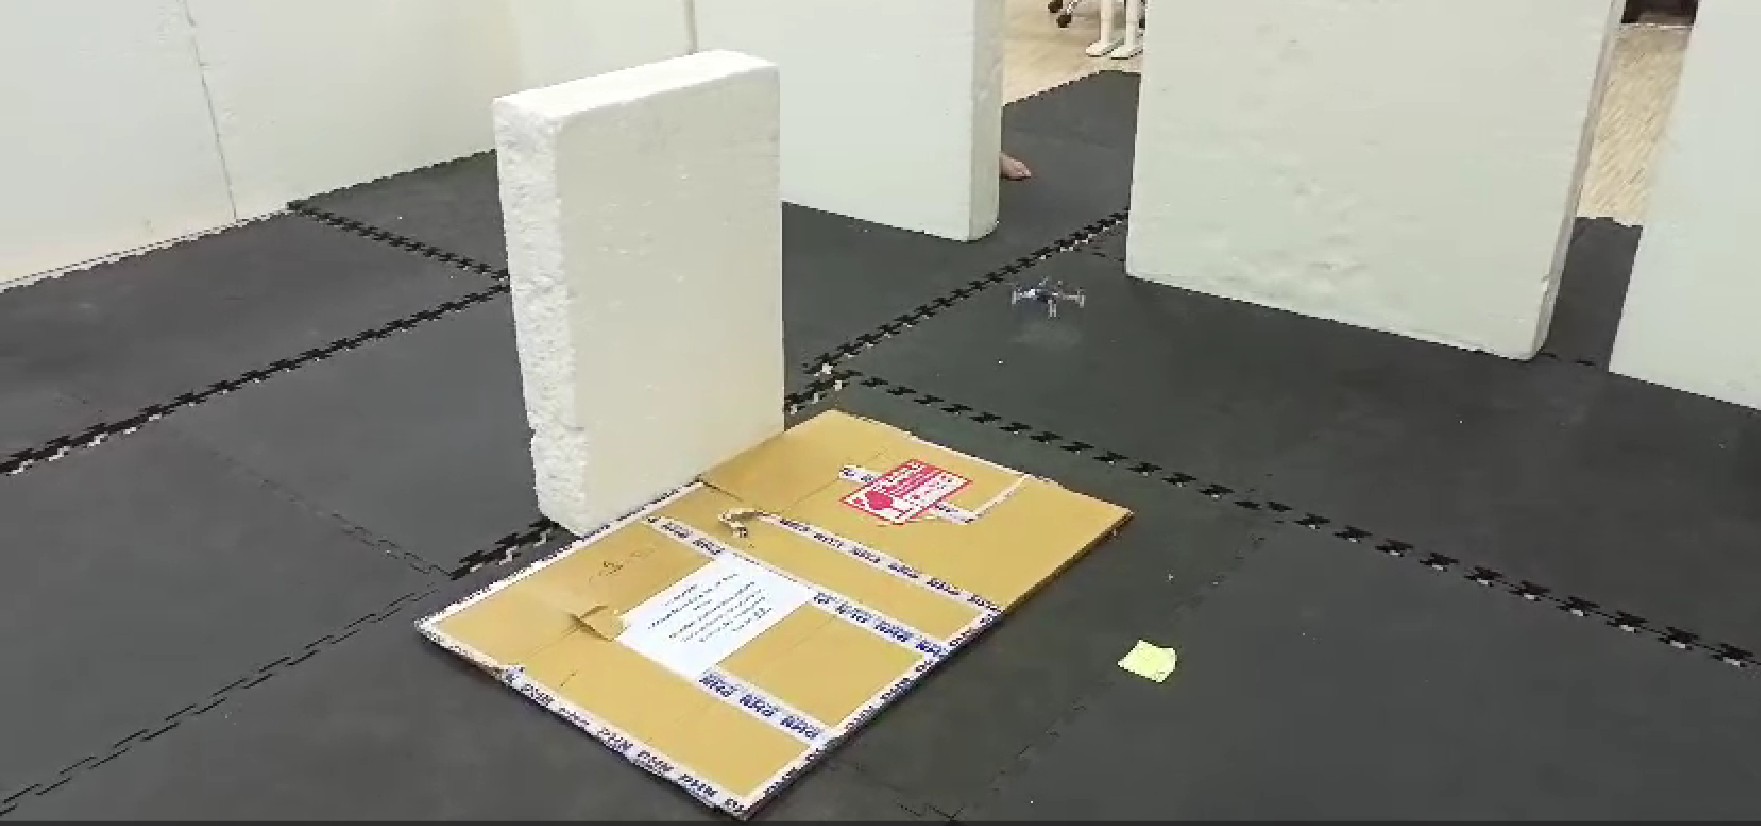
Formulated and implemented an open-loop 2D drone trajectory optimization framework with double-integrator dynamics, Runge-Kutta 4th Order (RK4) discretization, and a smooth Softplus-based non-convex obstacle penalty. Optimized via CasADi's IPOPT solver to balance control effort, jerk minimization, terminal goal-reaching, and collision avoidance.